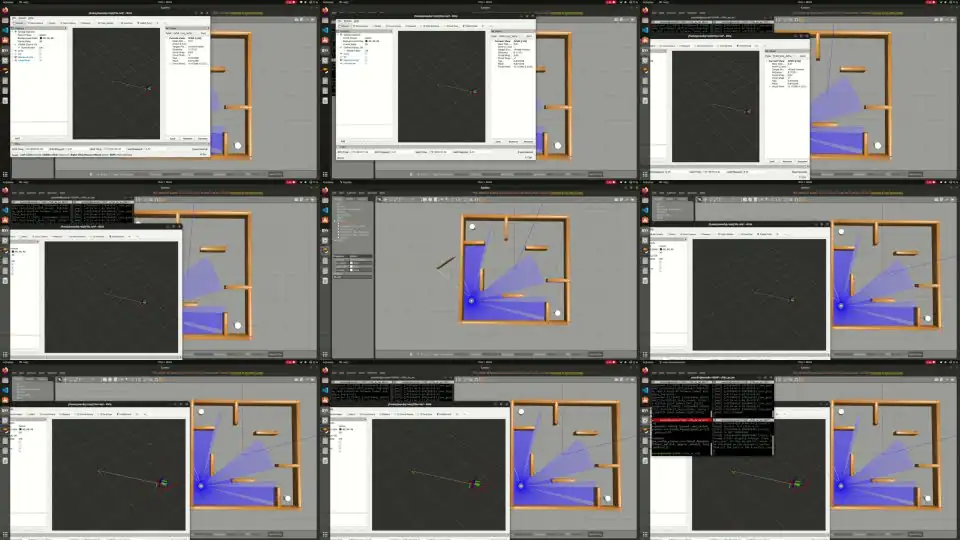
Custom Dynamic Window Approach (DWA) for ROS 2 Navigation and Autonomous Path Planning
Custom Dynamic Window Approach local planner for ROS 2, demonstrating trajectory sampling, cost optimization, and real-time obstacle avoidance on T...

Robotics engineer working across autonomy, perception, and embedded systems.
Selected work
Custom Dynamic Window Approach local planner for ROS 2, demonstrating trajectory sampling, cost optimization, and real-time obstacle avoidance on T...
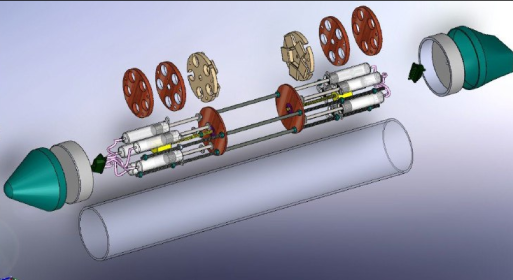
Surrogate ML framework for fast hydrodynamic parameter optimization of autonomous underwater gliders.

Design, analytical kinematics modeling, and control system for an open-source 12-DOF quadrupedal robot.
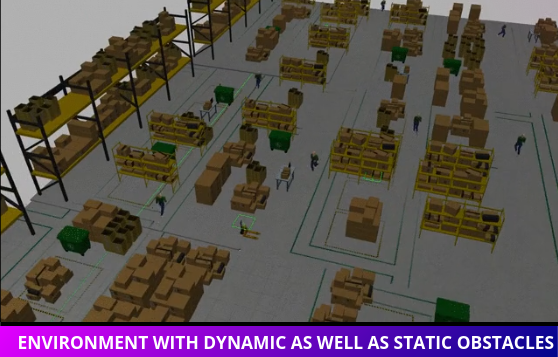
Centralized intelligence and dynamic obstacle forecasting for multi-agent swarm robot navigation using ROS 2 and YOLOv8.